PulseAugur
中
实时 21:35:13
中文(ZH) ICRA 2026 | 李飞飞团队:软物体移动操作新解法,“从刚到柔”的关键一步

Fei-Fei Li's team develops RAPID for deformable object manipulation

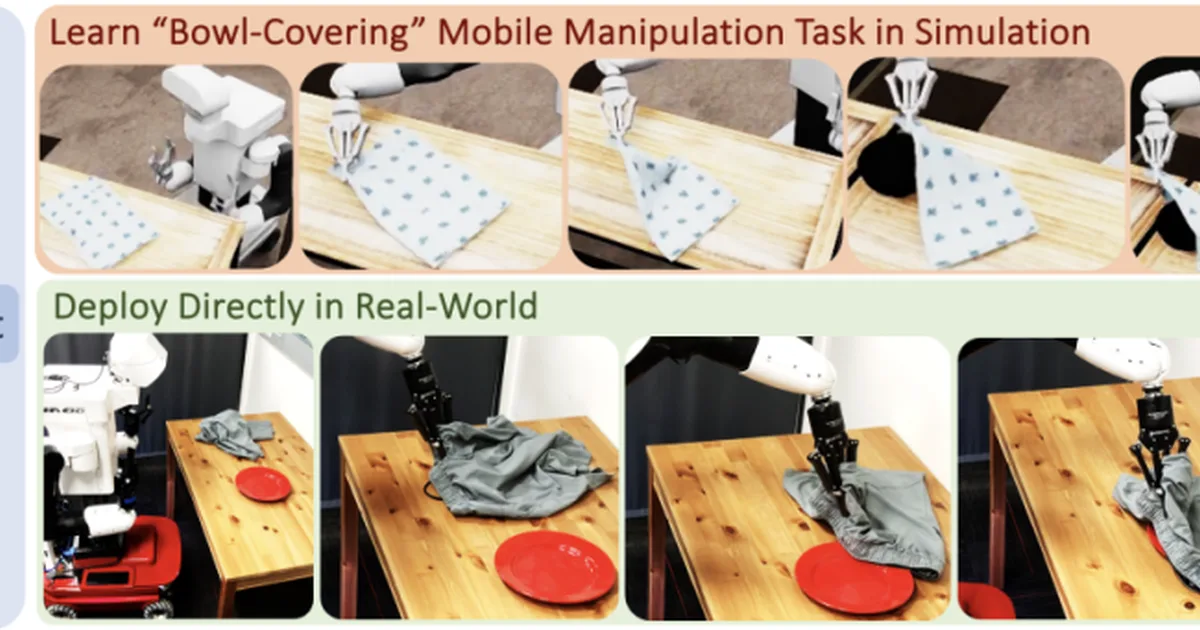
Fei-Fei Li团队的研究人员与德克萨斯大学奥斯汀分校合作,开发了一种名为RAPID(Rapid Adaptation of Particle Dynamics)的新型可变形物体操纵方法。该方法通过使用粒子位置来捕捉形状变化,将现有的刚体快速适应框架扩展到柔软、可变形的物体上。RAPID在对未见过物体和动力学的插入和覆盖任务中成功率超过80%,展示了向更通用的机器人操纵迈出的重要一步。 AI

影响 这项研究推进了机器人操纵能力,通过处理柔软和可变形的物品,有可能在制造、物流和医疗保健领域实现更复杂的自动化。

排序理由 该集群描述了一种在会议上提出的新研究方法。[lever_c_demoted from research: ic=1 ai=1.0]

在 雷峰网 (Leiphone) 阅读 →

AI 生成摘要 · Google Gemini · 来自 1 个来源。 我们如何撰写摘要 →
Fei-Fei Li's team develops RAPID for deformable object manipulation

本文如何被排名

Signal score
0 / 100
Composite score across the factors below. Higher = stronger signal that this story matters right now.
Newsworthiness bucket
Tool
该集群描述了一种在会议上提出的新研究方法。[lever_c_demoted from research: ic=1 ai=1.0]
Source corroboration
Single-source cluster
Only one publisher covered this so far. Single-source stories can still rank when the publisher is high-authority, but they lack cross-source corroboration.
Topics
paper, product
Editorial topic classification. Feeds into how the story surfaces on /topic/<slug> hub pages and into the per-entity coverage mix.
AI-industry relevance
High
Clearly on-topic for AI-industry coverage.
Story freshness
133 days old
Aged out of breaking-news scoring windows; ranking reflects the durable signal from the full source set.

完整方法见我们的编辑标准。

报道来源 [1]

  1. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | Fei-Fei Li团队:软体操控新解,刚性到软性关键一步

    <p><br /></p><p>原文作者:深蓝学院</p><p>原文链接:https://zhuanlan.zhihu.com/p/2020641171664282025</p><p><br /></p><p style="text-align: justify;"><span><img class="rich_pages wxw-img" href="//mmbiz.qpic.cn/mmbiz_png/uwFbeBKoFGeLibPx7Ribh1koicNlPromrwK8hNjJtsoBpPsuyaRqcaxbxmic16L7znNNaujdWGdh…