PulseAugur
中
实时 08:34:16
中文(ZH) ICRA 2026|EFM: 探索性与聚焦性机器人操作

机器人通过新的KAN-We-Flow和EFM策略提高效率

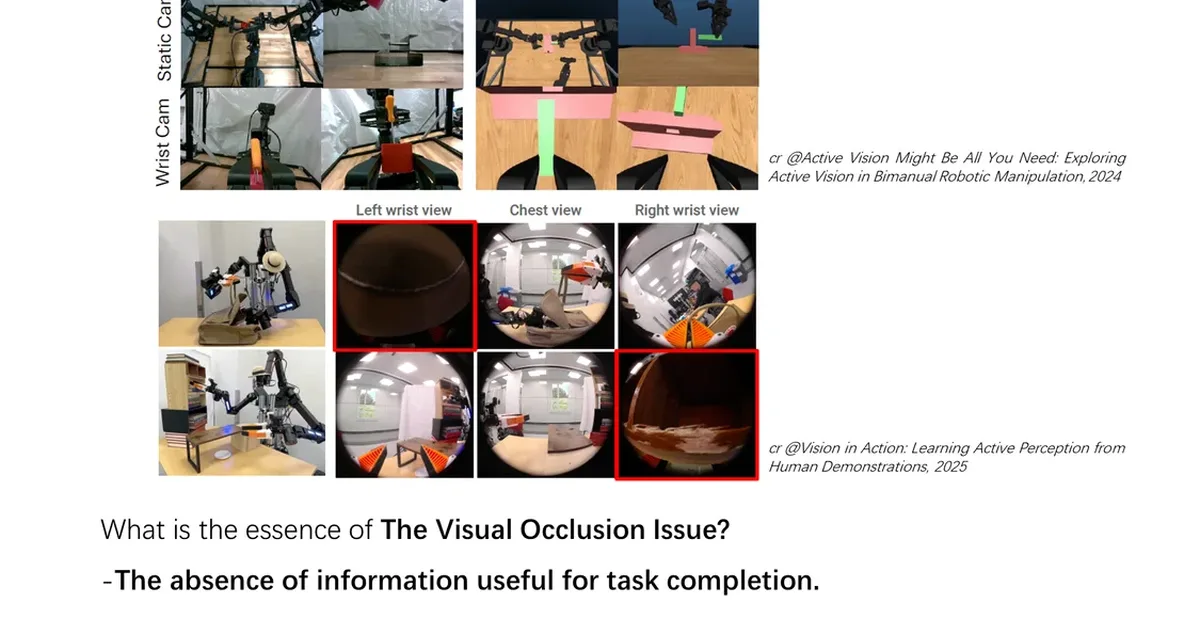
研究人员开发了KAN-We-Flow,一种新颖的机器人操作策略,利用RWKV和KAN显著减小模型尺寸和推理延迟,同时保持或提高成功率。该方法在Adroit和Meta-World等基准测试中取得了最先进的性能,参数减少了86.8%,并具备实时控制能力。此外,引入了一个名为EFM-10的新基准,通过专注于探索性和专注性操作策略来解决人形双臂操作中的挑战,特别是视觉遮挡问题。该基准以及BAPData数据集和BAP策略旨在使机器人能够主动获取复杂任务所需的必要信息。 AI

影响 新模型和基准有望实现更高效、更强大的机器人操作,可能加速其在复杂现实世界任务中的应用。

排序理由 该集群描述了机器人操作领域的新研究论文和方法论,包括新颖的模型和基准。

在 雷峰网 (Leiphone) 阅读 →

AI 生成摘要 · Google Gemini · 来自 2 个来源。 我们如何撰写摘要 →
机器人通过新的KAN-We-Flow和EFM策略提高效率

本文如何被排名

Signal score
0 / 100
Composite score across the factors below. Higher = stronger signal that this story matters right now.
Newsworthiness bucket
Research
该集群描述了机器人操作领域的新研究论文和方法论,包括新颖的模型和基准。
Source corroboration
2 independent sources
Multiple independent publishers reporting the same story raises confidence that it's real and newsworthy.
Topics
model release, paper, product
Editorial topic classification. Feeds into how the story surfaces on /topic/<slug> hub pages and into the per-entity coverage mix.
AI-industry relevance
High
Clearly on-topic for AI-industry coverage.
Story freshness
124 days old
Aged out of breaking-news scoring windows; ranking reflects the durable signal from the full source set.

完整方法见我们的编辑标准。

报道来源 [2]

  1. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | KAN We Flow? (机器人控制)

    <p style="margin-top: 0; margin-bottom: 0;">&nbsp;</p><p style="margin-top: 0; margin-bottom: 0;">原文作者:用户“多多的贾维斯”</p><p>原文链接:<a href="https://www.xiaohongshu.com/" rel="nofollow" target="_blank">https://www.xiaohongshu.com/</a> </p><p><br /></p><p style="margin-top: 0px; margin-b…

  2. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | EFM:探索性与聚焦式机器人操作

    <p style="text-align: left; margin-top: 0; margin-bottom: 0;"></p><p style="margin-top: 0; margin-bottom: 0;">原文作者:RIL-Lab</p><p style="margin-top: 0; margin-bottom: 0;">实验室ICRA2026录用论文 (https://arxiv.org/abs/2602.01939)。</p><p style="margin-top: 0px; margin-bottom: 0px; text-ali…