PulseAugur
EN
LIVE 05:52:41
中文(ZH) ICRA 2026|山西大学本科生一作:TacTip动态触觉流实现力估计与力跟踪

Shanxi University develops dynamic tactile force estimation for robots

Researchers from Shanxi University have developed a novel framework for dynamic tactile force estimation using sequential tactile images, specifically designed for TacTip sensors. This approach captures spatio-temporal features to accurately model changes in dynamic forces, offering a new solution for robotic force control in real-world interactions. The method has demonstrated effectiveness in dynamic scenarios like robotic force tracking during surface slippage, addressing limitations of traditional static calibration methods. AI

IMPACT Enhances robotic manipulation and interaction capabilities by enabling more precise force control in dynamic environments.

RANK_REASON Academic paper accepted to a top-tier robotics conference (ICRA 2026) detailing a novel method for tactile force estimation. [lever_c_demoted from research: ic=1 ai=1.0]

Read on 雷峰网 (Leiphone) →

AI-generated summary · Google Gemini · from 1 sources. How we write summaries →
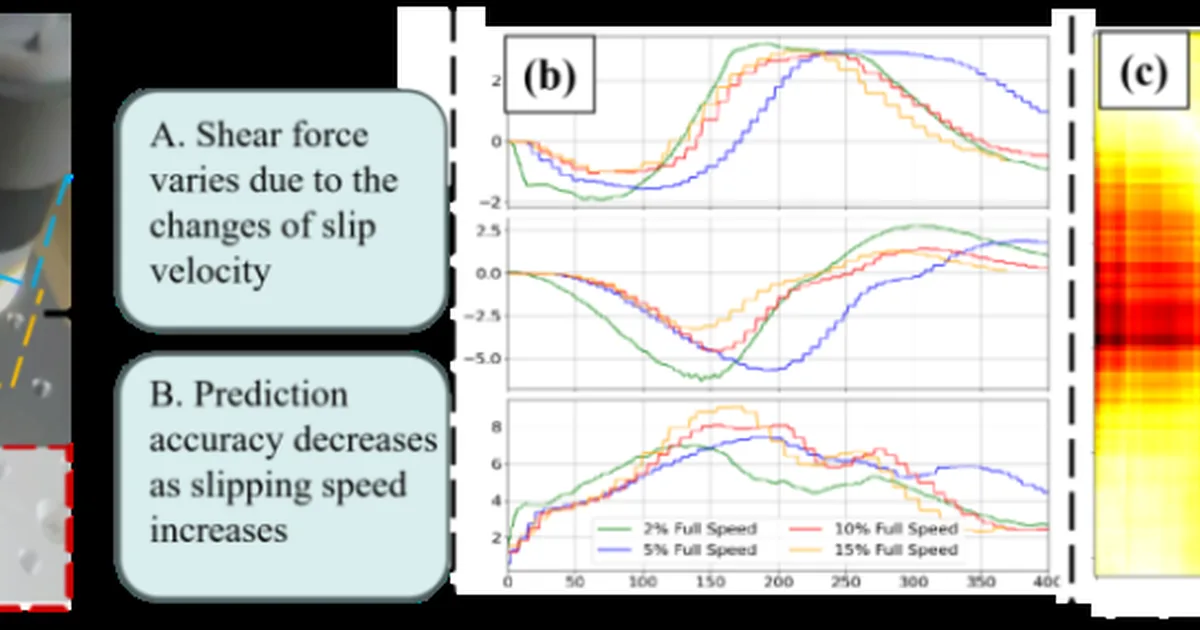
Shanxi University develops dynamic tactile force estimation for robots

How we ranked this

Signal score
0 / 100
Composite score across the factors below. Higher = stronger signal that this story matters right now.
Newsworthiness bucket
Tool
Academic paper accepted to a top-tier robotics conference (ICRA 2026) detailing a novel method for tactile force estimation. [lever_c_demoted from research: ic=1 ai=1.0]
Source corroboration
Single-source cluster
Only one publisher covered this so far. Single-source stories can still rank when the publisher is high-authority, but they lack cross-source corroboration.
Topics
paper, product
Editorial topic classification. Feeds into how the story surfaces on /topic/<slug> hub pages and into the per-entity coverage mix.
AI-industry relevance
High
Clearly on-topic for AI-industry coverage.
Story freshness
121 days old
Aged out of breaking-news scoring windows; ranking reflects the durable signal from the full source set.

Full methodology in our editorial standards.

COVERAGE [1]

  1. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | Shanxi University Undergraduate First Author: TacTip Dynamic Tactile Flow Achieves Force Estimation and Force Tracking

    <p style="margin-top: 0; margin-bottom: 0;"><br /></p><p style="margin-top: 0; margin-bottom: 0;">原文作者:公众号“CCF太原分部“</p><p style="margin-top: 0; margin-bottom: 0;">原文链接:https://mp.weixin.qq.com/s/qWB_shGkHy23EgRFrxr1Jw</p><p>&nbsp;</p><p style="margin-bottom: 8pt;">近日,论文录用结果正式发布,山…