PulseAugur
EN
LIVE 00:43:54
中文(ZH) ICRA 2026|EFM: 探索性与聚焦性机器人操作

Robots gain efficiency with new KAN-We-Flow and EFM strategies

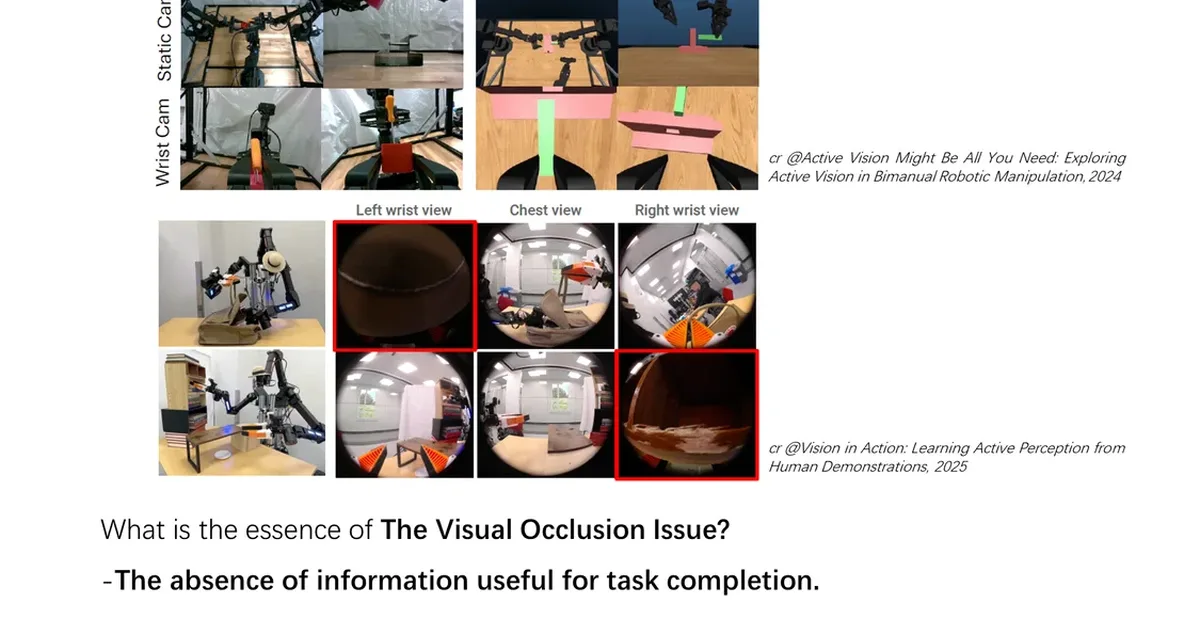
Researchers have developed KAN-We-Flow, a novel strategy for robotic manipulation that utilizes RWKV and KAN to significantly reduce model size and inference latency while maintaining or improving success rates. This method achieves state-of-the-art performance on benchmarks like Adroit and Meta-World, with an 86.8% reduction in parameters and real-time control capabilities. Separately, a new benchmark called EFM-10 has been introduced to address challenges in humanoid dual-arm manipulation, particularly visual occlusion, by focusing on exploratory and focused manipulation strategies. This benchmark, along with the BAPData dataset and BAP strategy, aims to enable robots to actively acquire necessary information for complex tasks. AI

IMPACT New models and benchmarks promise more efficient and capable robotic manipulation, potentially accelerating adoption in complex real-world tasks.

RANK_REASON The cluster describes new research papers and methodologies in robotic manipulation, including novel models and benchmarks.

Read on 雷峰网 (Leiphone) →

AI-generated summary · Google Gemini · from 2 sources. How we write summaries →
Robots gain efficiency with new KAN-We-Flow and EFM strategies

How we ranked this

Signal score
0 / 100
Composite score across the factors below. Higher = stronger signal that this story matters right now.
Newsworthiness bucket
Research
The cluster describes new research papers and methodologies in robotic manipulation, including novel models and benchmarks.
Source corroboration
2 independent sources
Multiple independent publishers reporting the same story raises confidence that it's real and newsworthy.
Topics
model release, paper, product
Editorial topic classification. Feeds into how the story surfaces on /topic/<slug> hub pages and into the per-entity coverage mix.
AI-industry relevance
High
Clearly on-topic for AI-industry coverage.
Story freshness
121 days old
Aged out of breaking-news scoring windows; ranking reflects the durable signal from the full source set.

Full methodology in our editorial standards.

COVERAGE [2]

  1. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | KAN We Flow? (Robotics Control)

    <p style="margin-top: 0; margin-bottom: 0;">&nbsp;</p><p style="margin-top: 0; margin-bottom: 0;">原文作者:用户“多多的贾维斯”</p><p>原文链接:<a href="https://www.xiaohongshu.com/" rel="nofollow" target="_blank">https://www.xiaohongshu.com/</a> </p><p><br /></p><p style="margin-top: 0px; margin-b…

  2. 雷峰网 (Leiphone) TIER_1 中文(ZH) ·

    ICRA 2026 | EFM: Exploratory and Focused Robotic Manipulation

    <p style="text-align: left; margin-top: 0; margin-bottom: 0;"></p><p style="margin-top: 0; margin-bottom: 0;">原文作者:RIL-Lab</p><p style="margin-top: 0; margin-bottom: 0;">实验室ICRA2026录用论文 (https://arxiv.org/abs/2602.01939)。</p><p style="margin-top: 0px; margin-bottom: 0px; text-ali…